01 — Case studies
Featured projects
Full write-ups with photos, videos, and code.
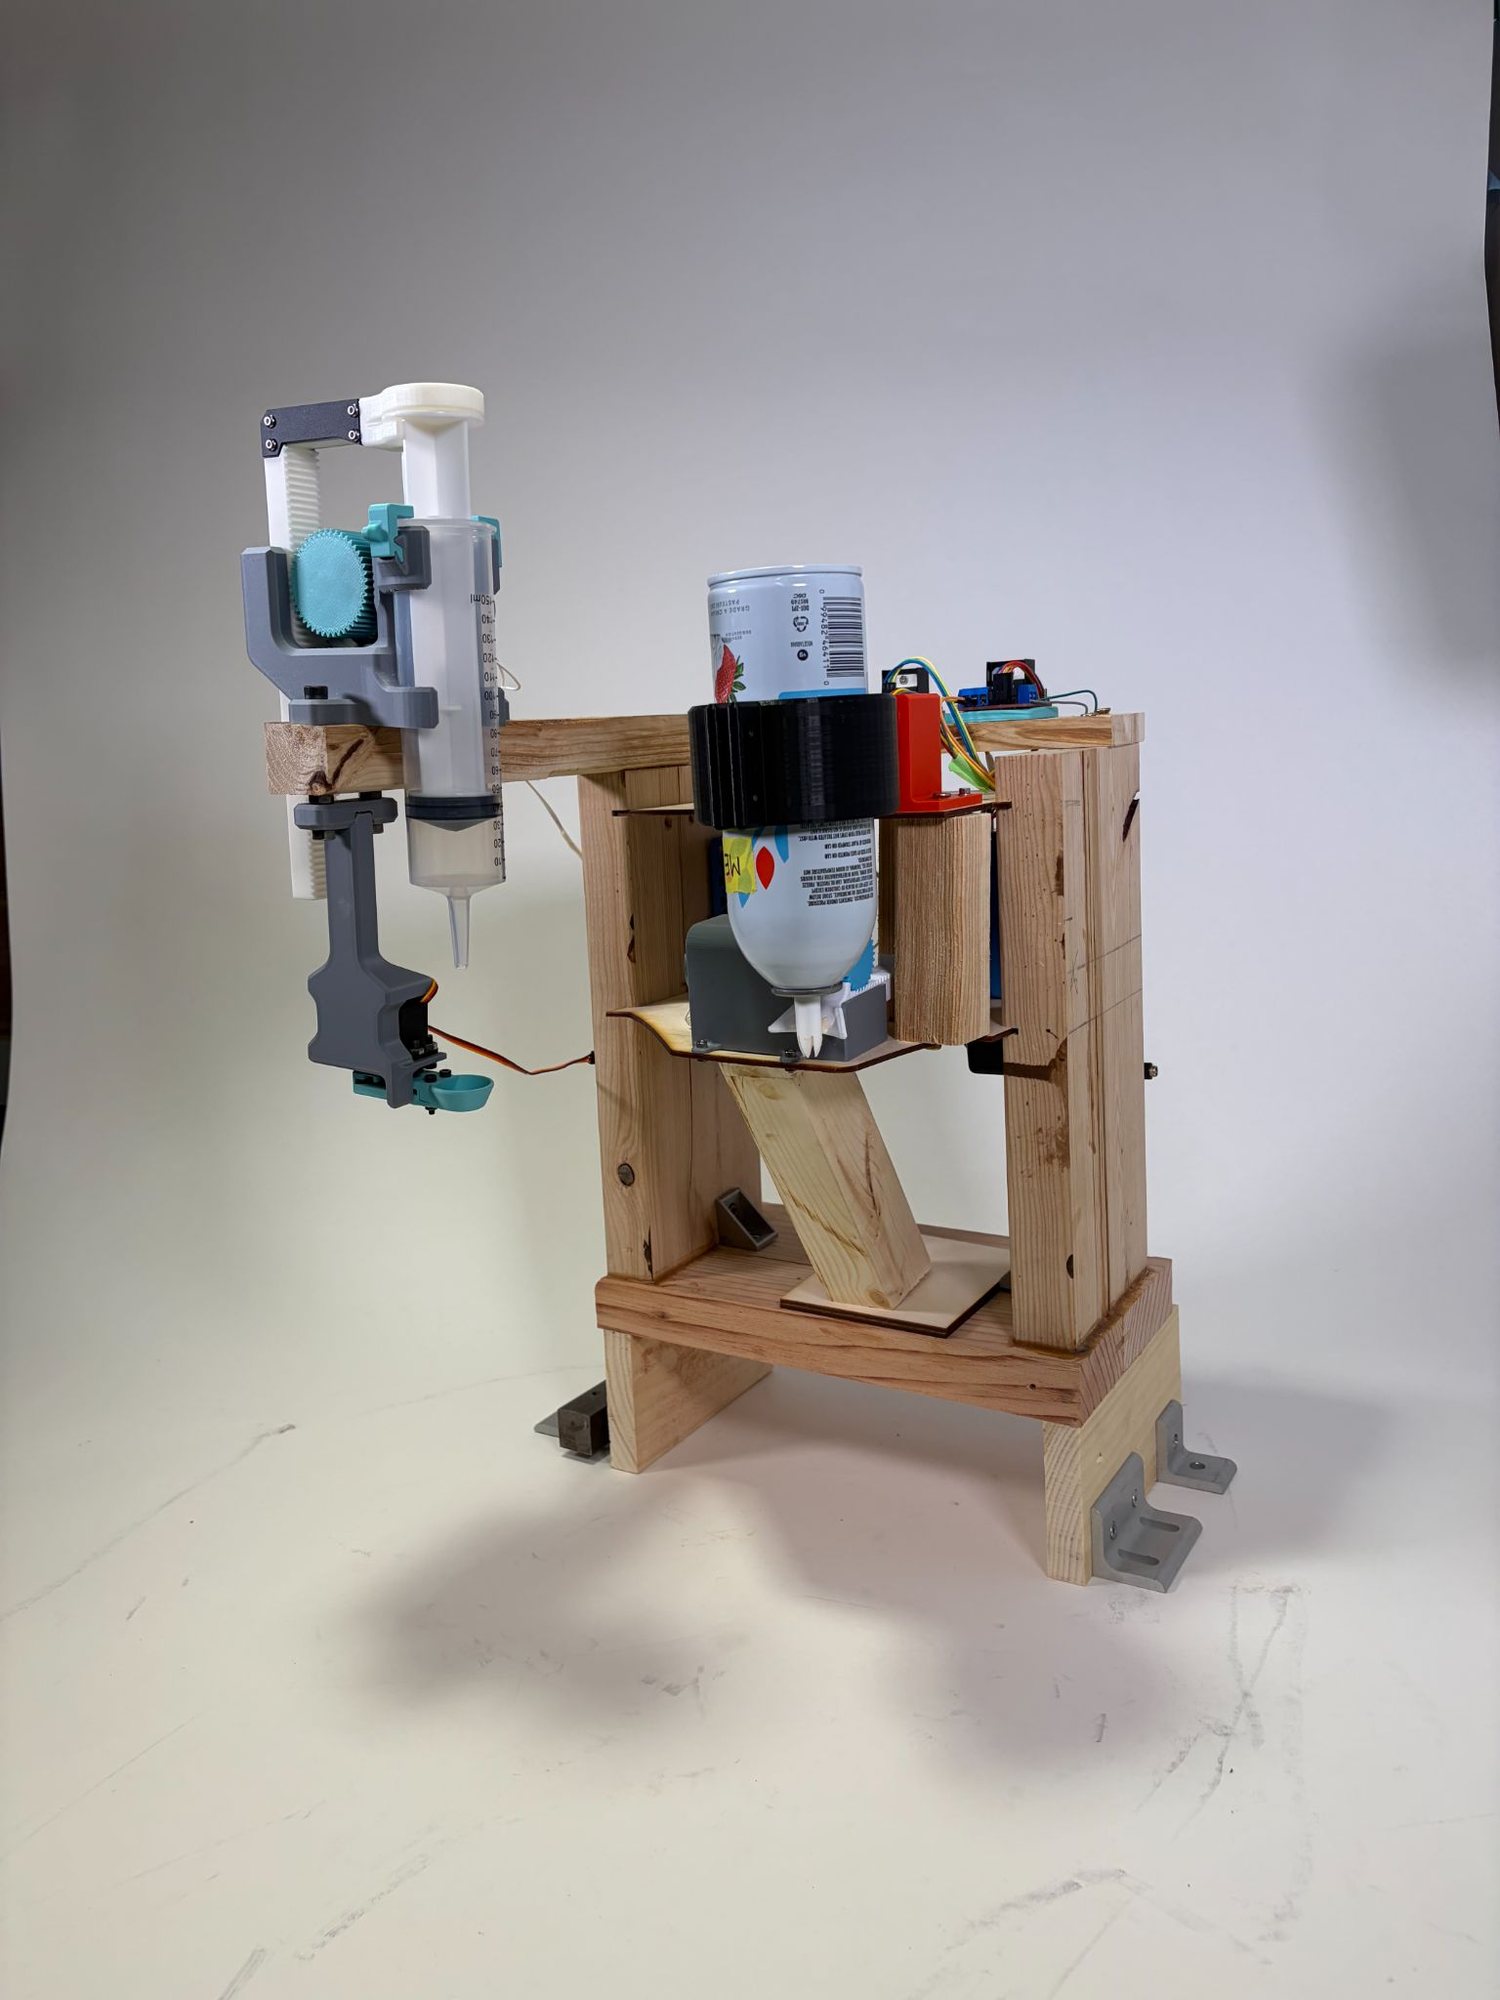
Waffle House
Fully automated waffle-making line: coordinated robotic stations, web-based ordering, and a mobile Create 3 platform tying it all together.
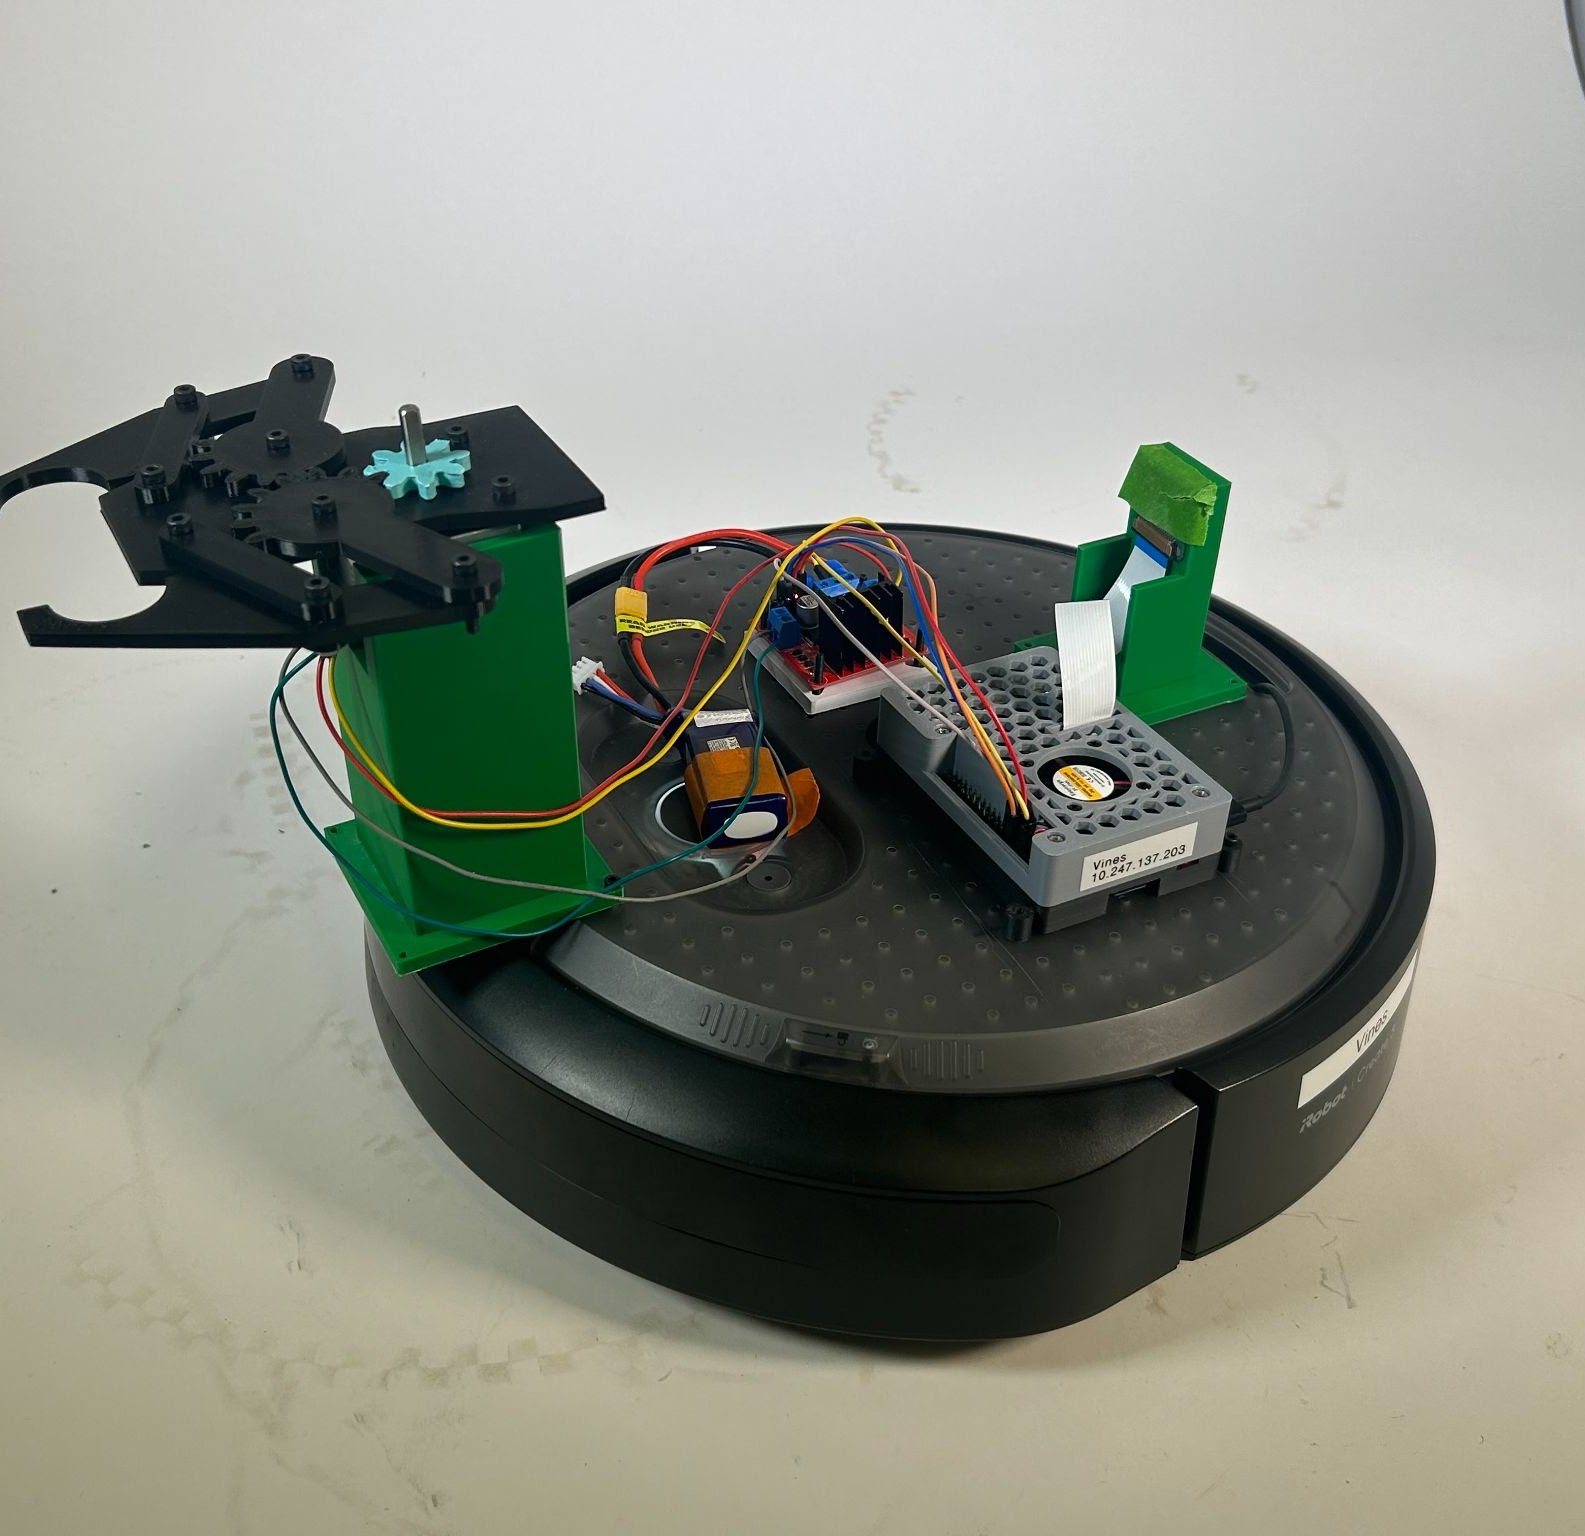
Create 3 Object Recognition
Autonomous warehouse-style pick-and-place robot that identifies characters with a neural network and delivers them without human intervention.
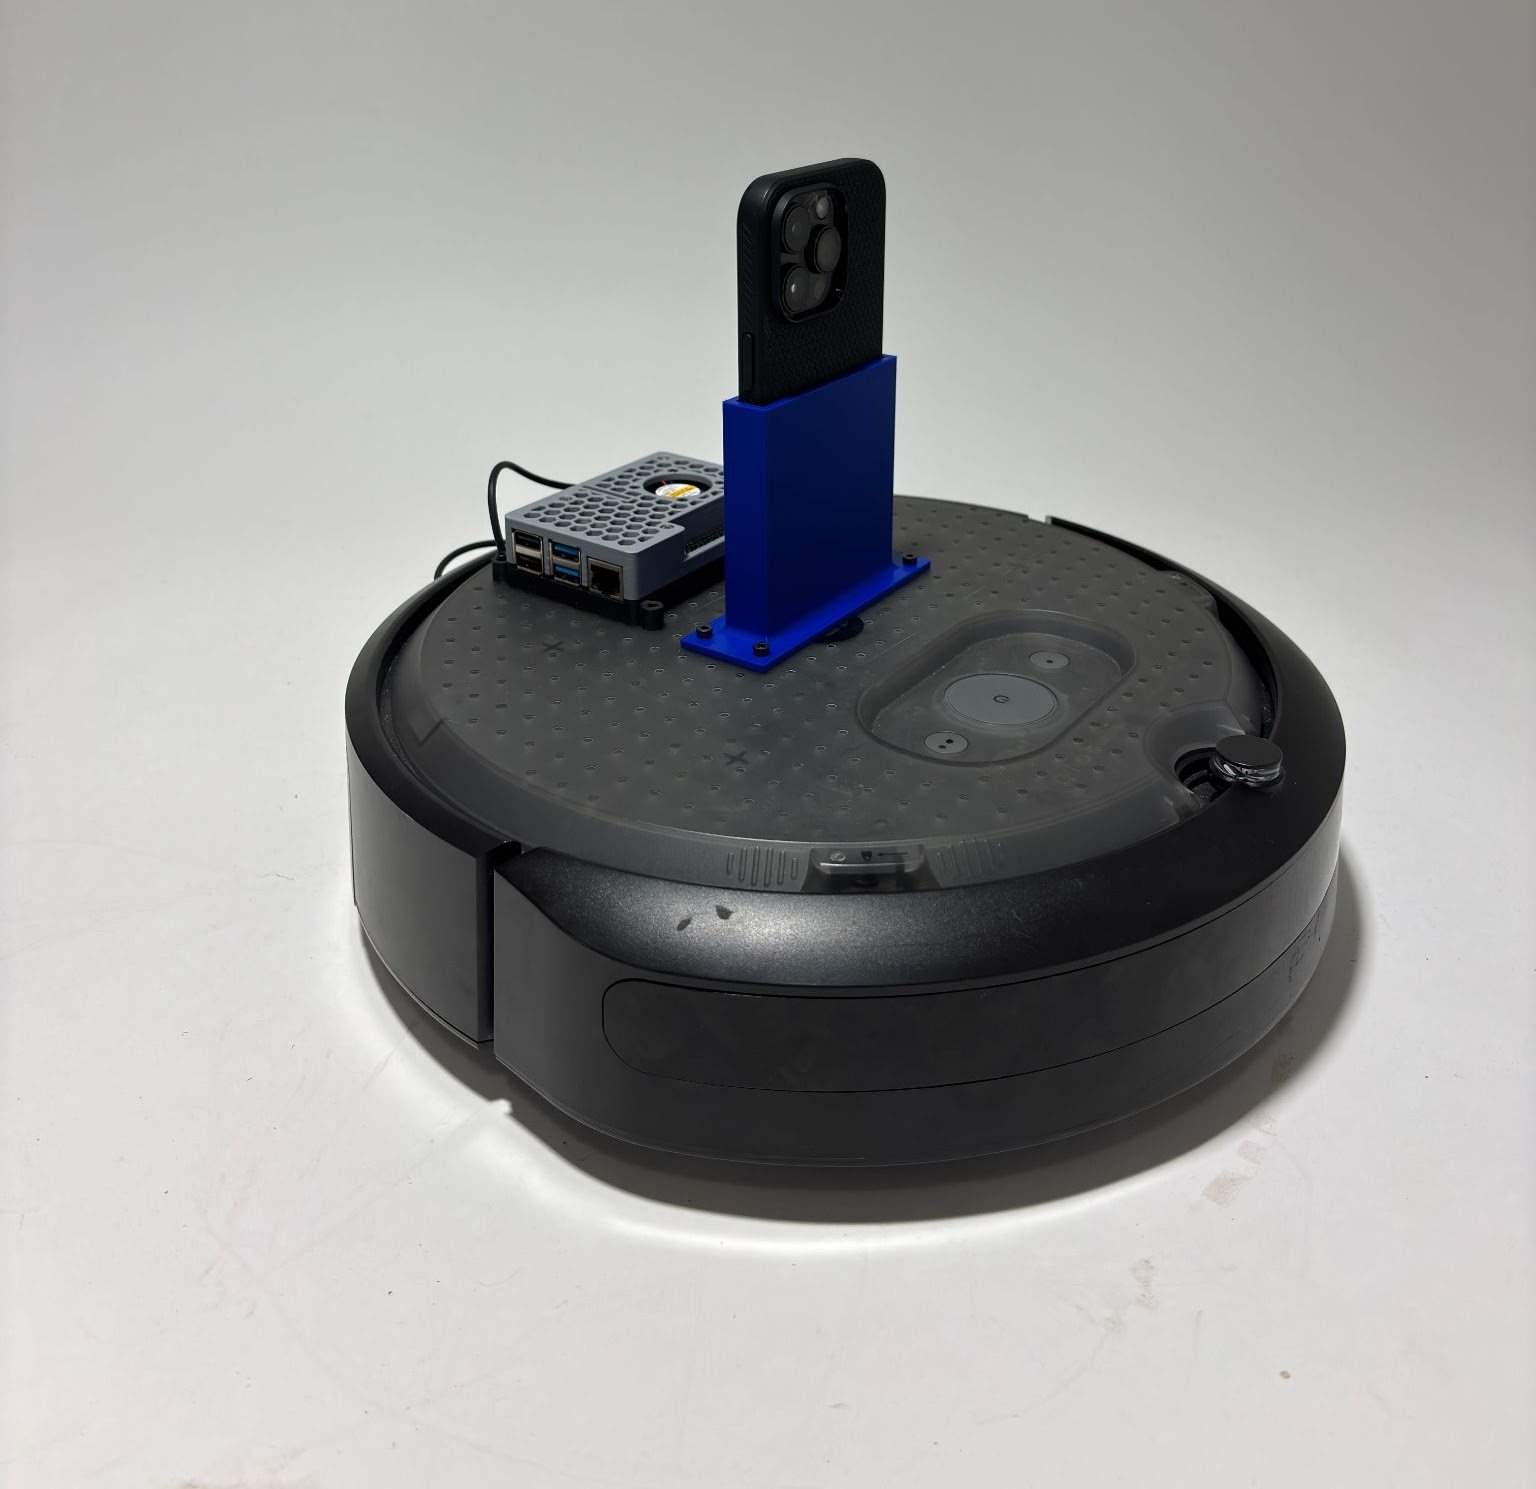
Create 3 Airtable Navigation
Remote teleoperation of an iRobot Create 3 through a maze, using Airtable as a real-time command bus with live camera feedback.
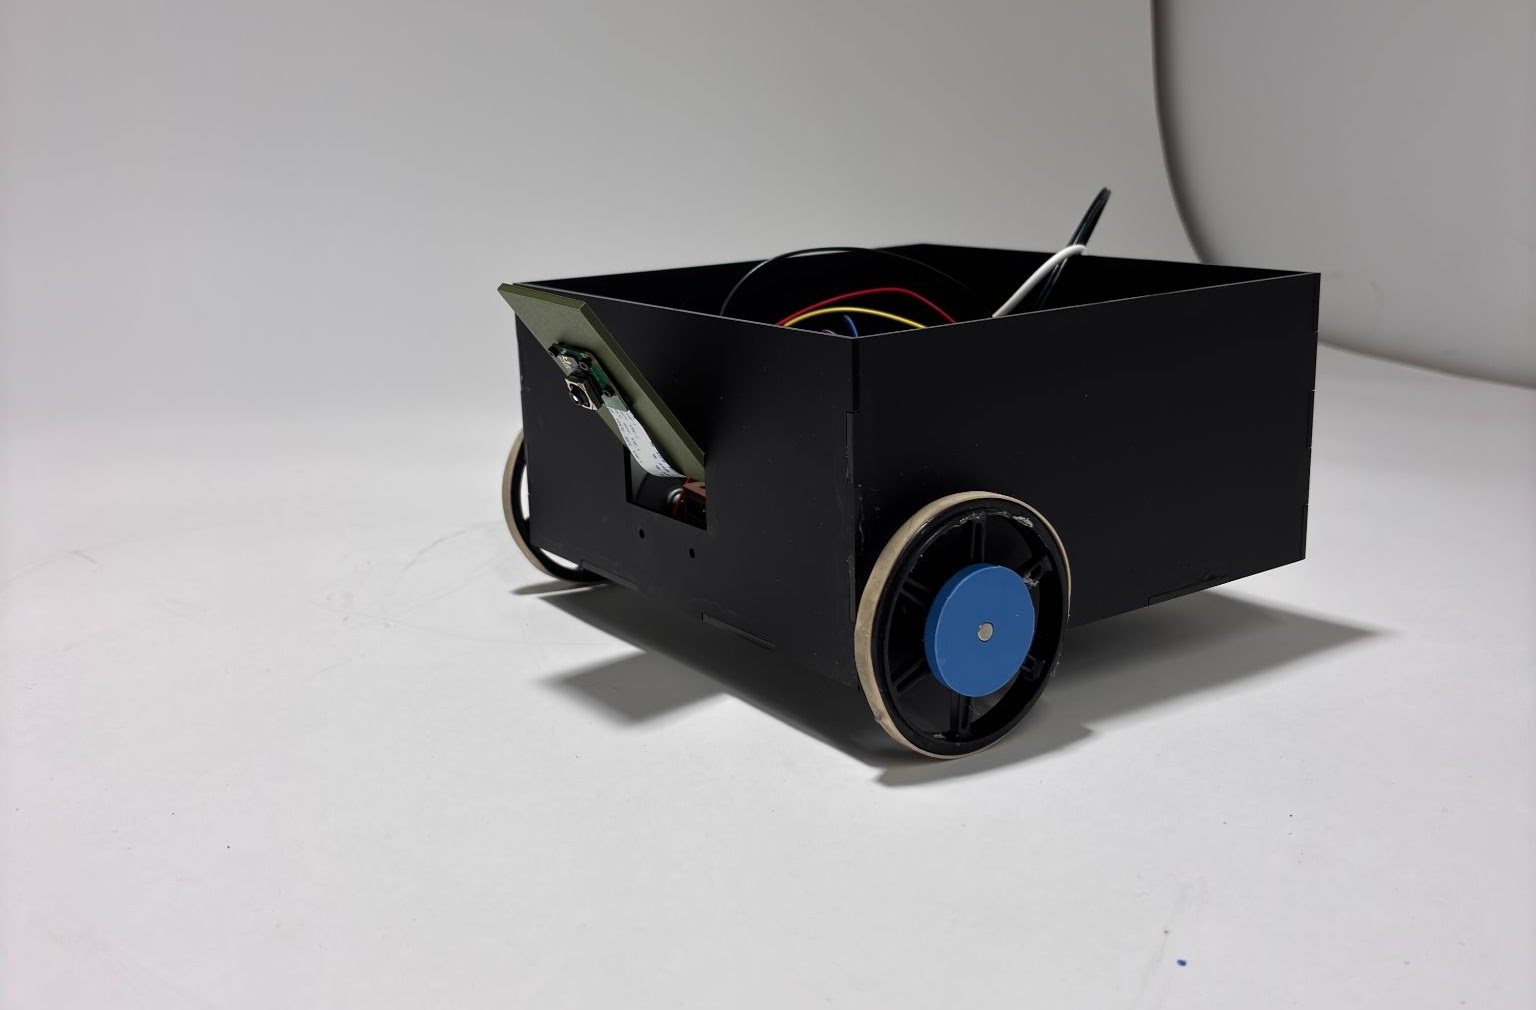
Camera Line Follower
Autonomous robot that tracks a line using a Raspberry Pi camera and OpenCV computer vision, with a search routine for lost-line recovery.
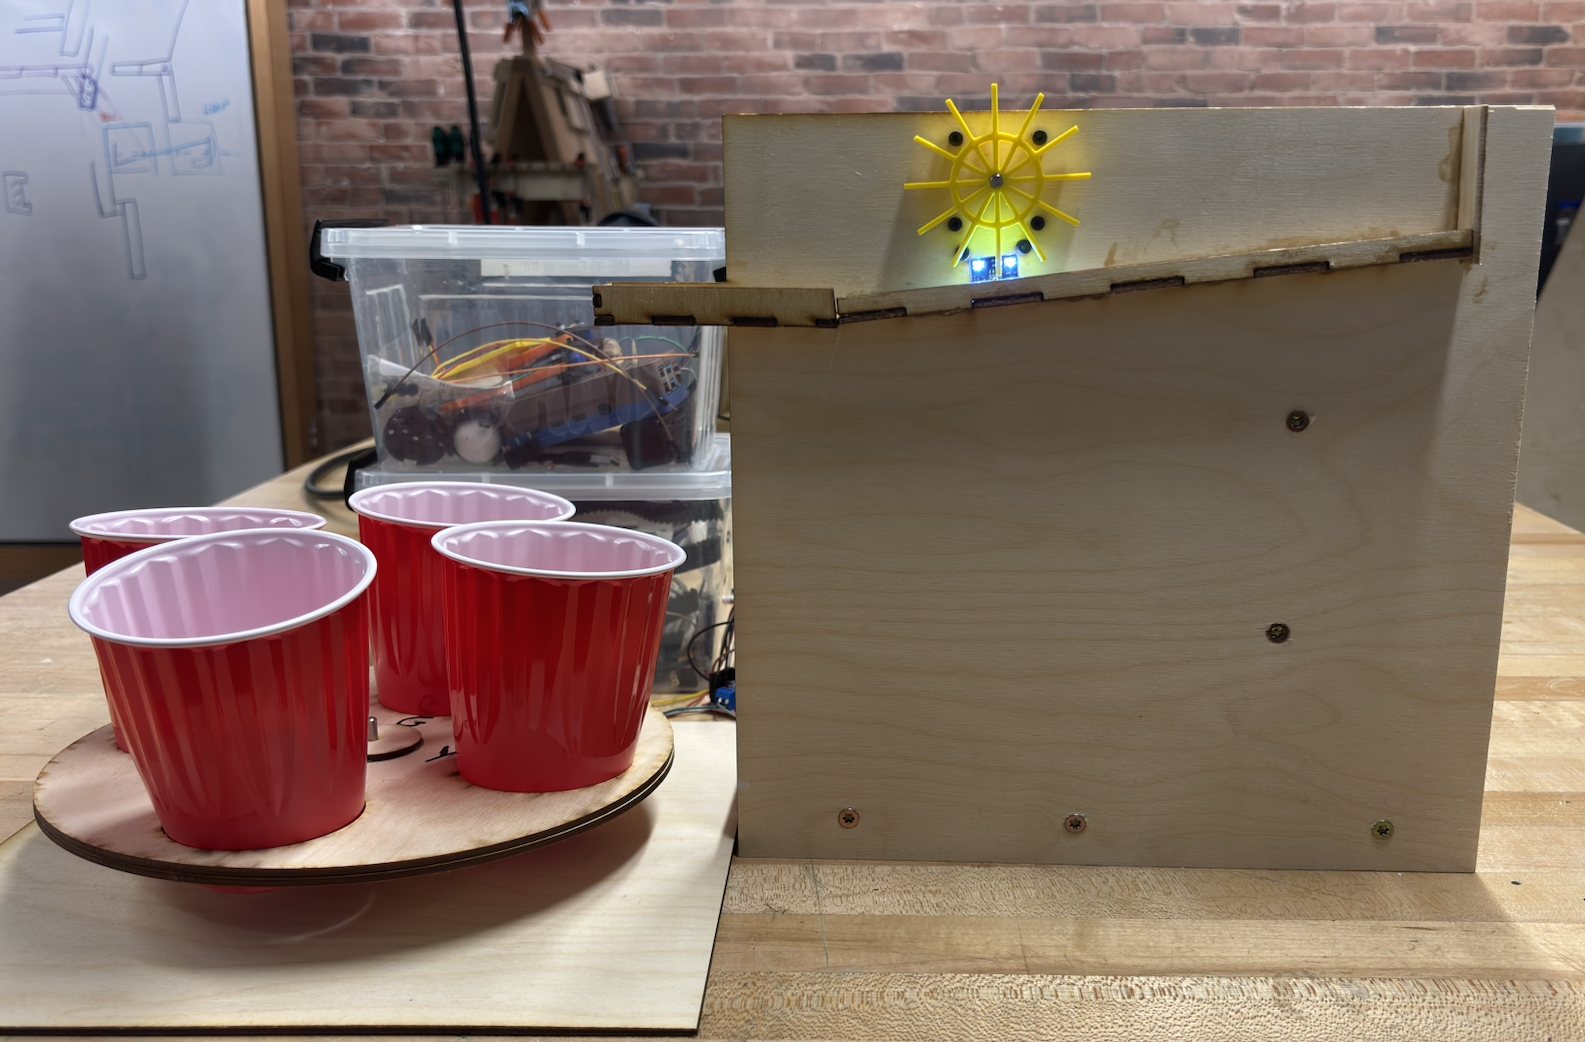
Ball Sorter
Autonomous system that sorts randomly mixed colored balls into color-specific outputs using a color sensor and dual stepper motors.
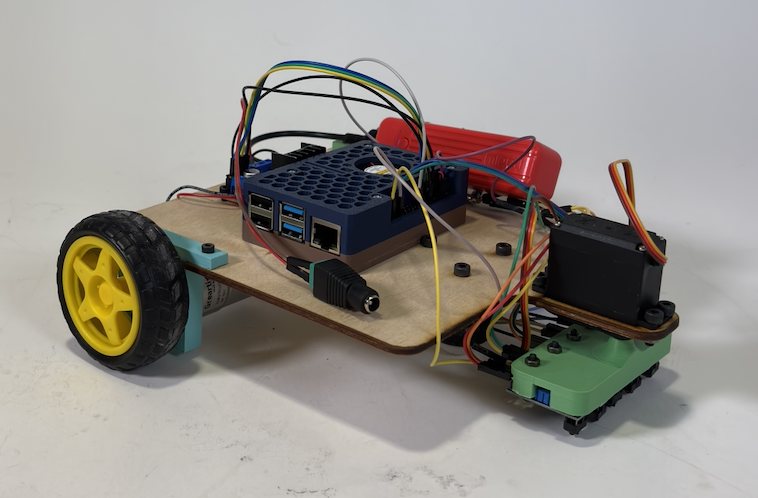
Line Follower
Custom-built robot that follows a path with IR sensors, reaches the end, turns around, and returns — on a fully hand-fabricated chassis.
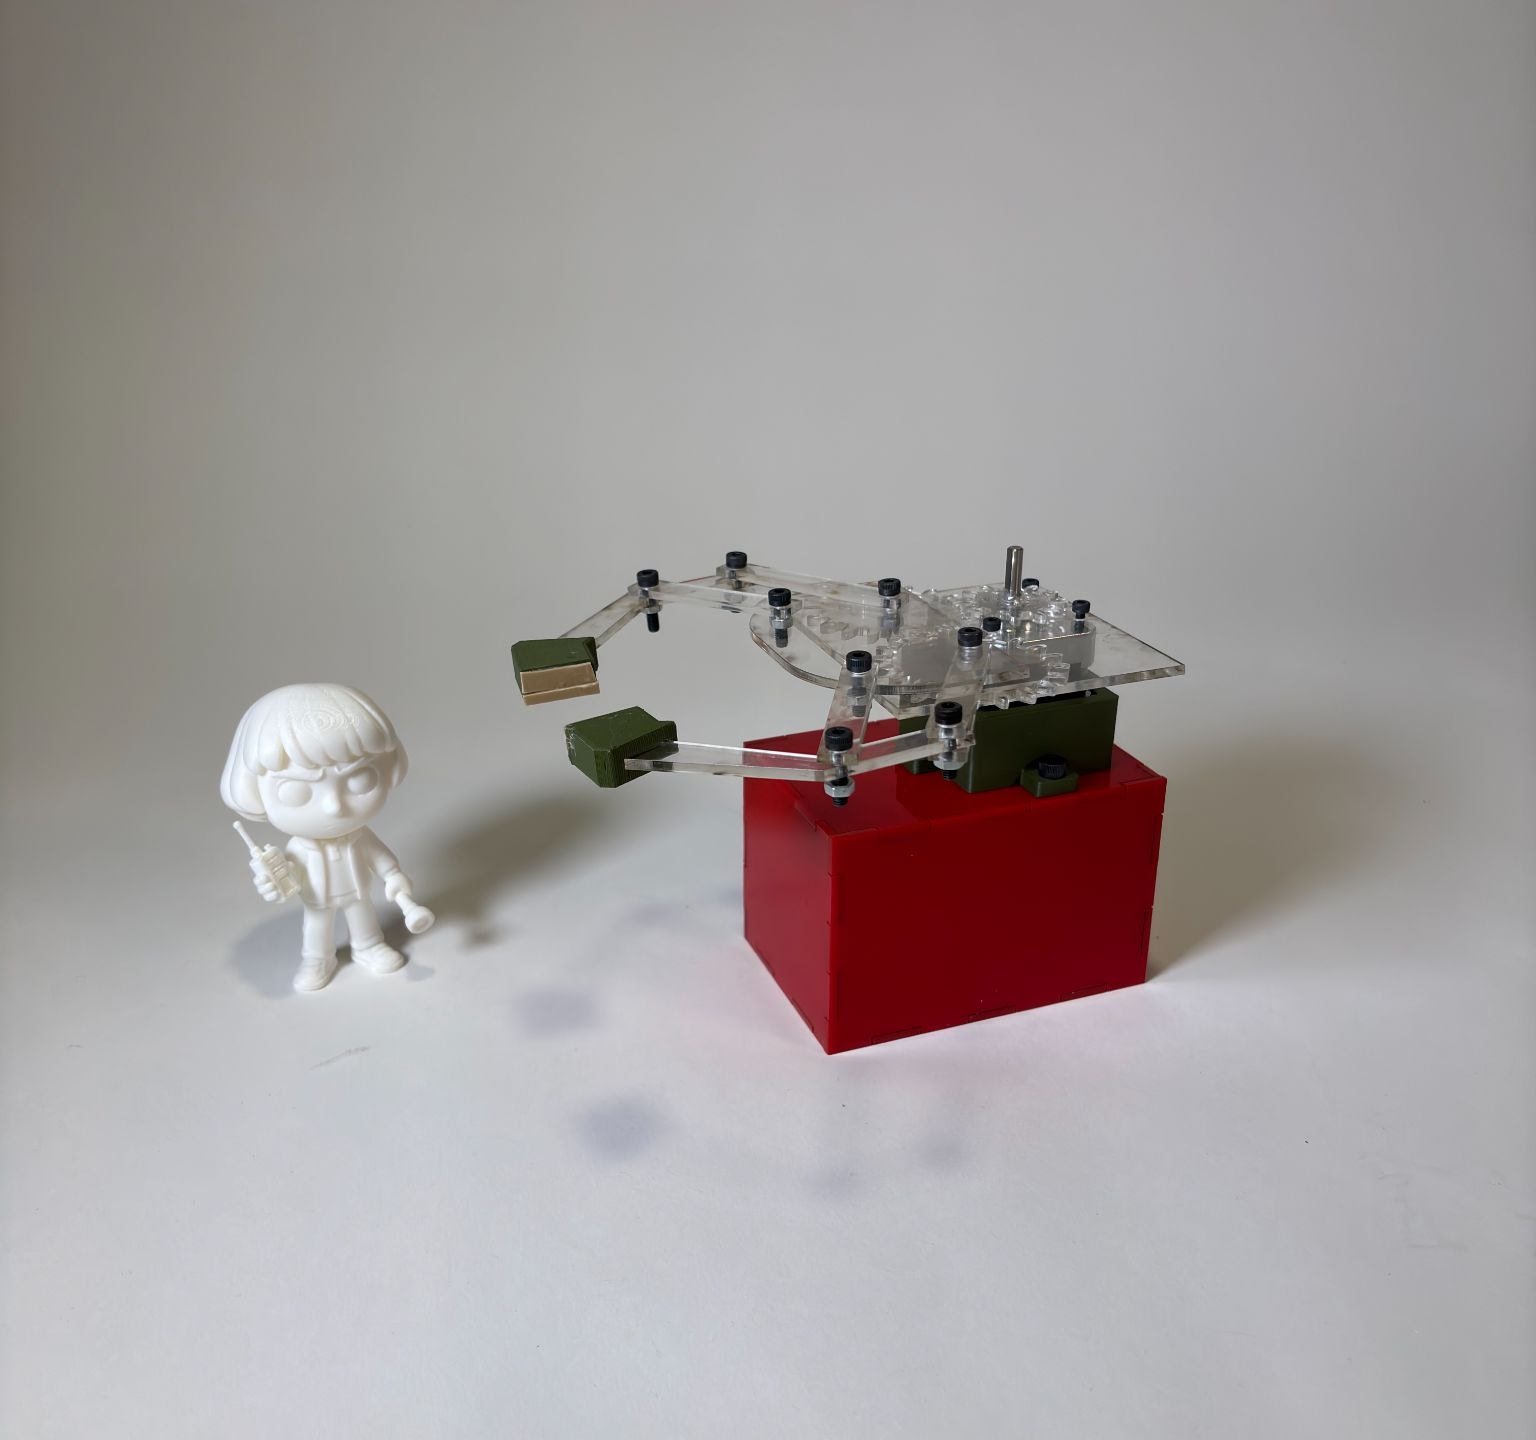
Demogorgon Grip
Original mechanical gripper using linkages, gears, and a stepper motor that autonomously grasps and transports a figure.
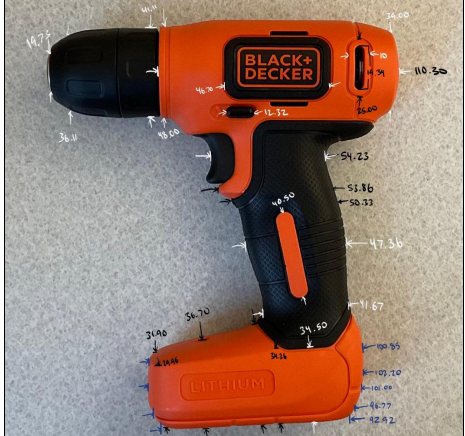
Drill Product Teardown
Full decomposition and study of a Black & Decker drill — documented, sorted into subsystems, and modeled in SolidWorks.
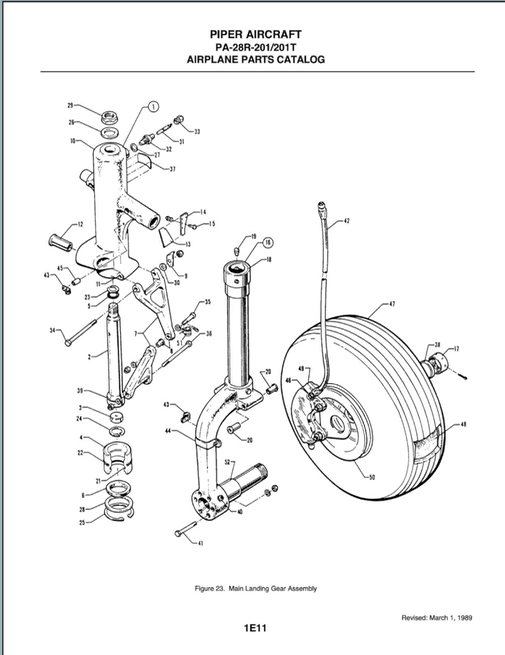
Piper Arrow Landing Gear
CAD decomposition of a Piper Arrow's landing gear — 52 parts and 6 assemblies modeled from the parts catalog alone, plus a Simulink simulation.
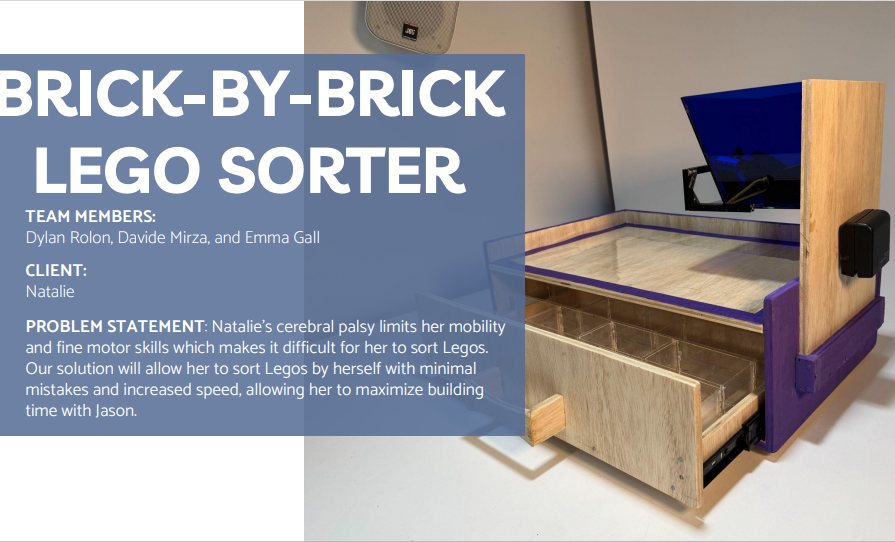
Lego Sorter — Assistive Device
Assistive device that lets Natalie, a client with cerebral palsy, sort Legos independently — faster and with fewer mistakes.
Assistive Technology Hackathon
Co-designed a custom adjustable switch holder so Hamza can play his favorite PlayStation games with his feet — within a $100 budget.
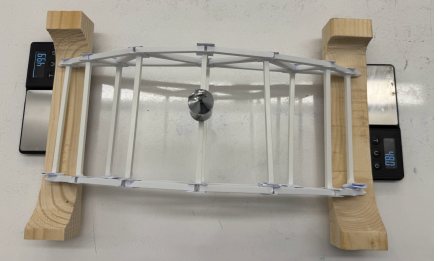
Truss Analysis
Design, build, and analysis of a statically determinate truss — hand calculations verified against MATLAB and an online solver.